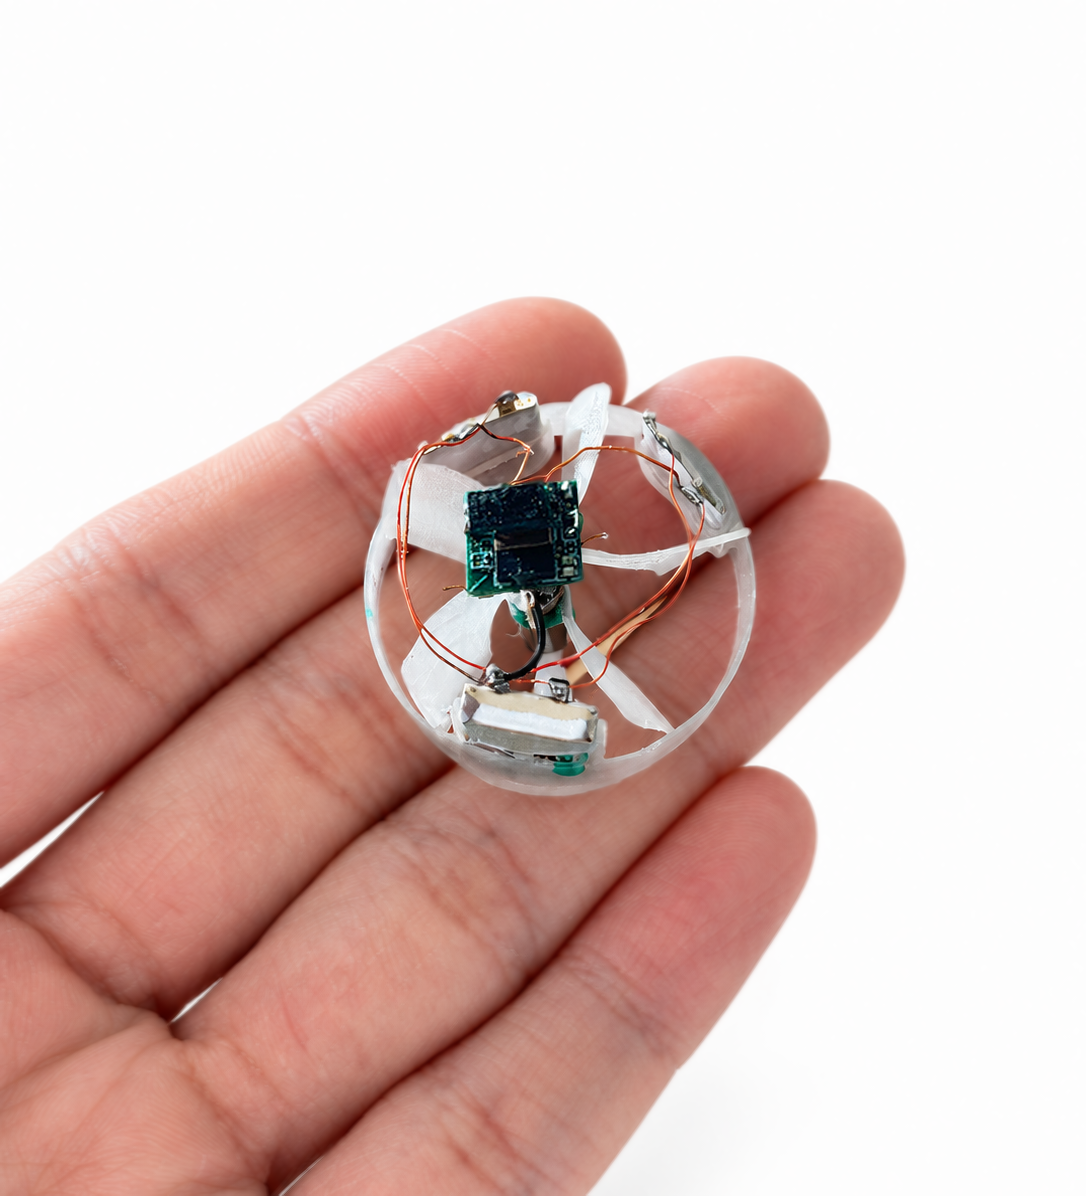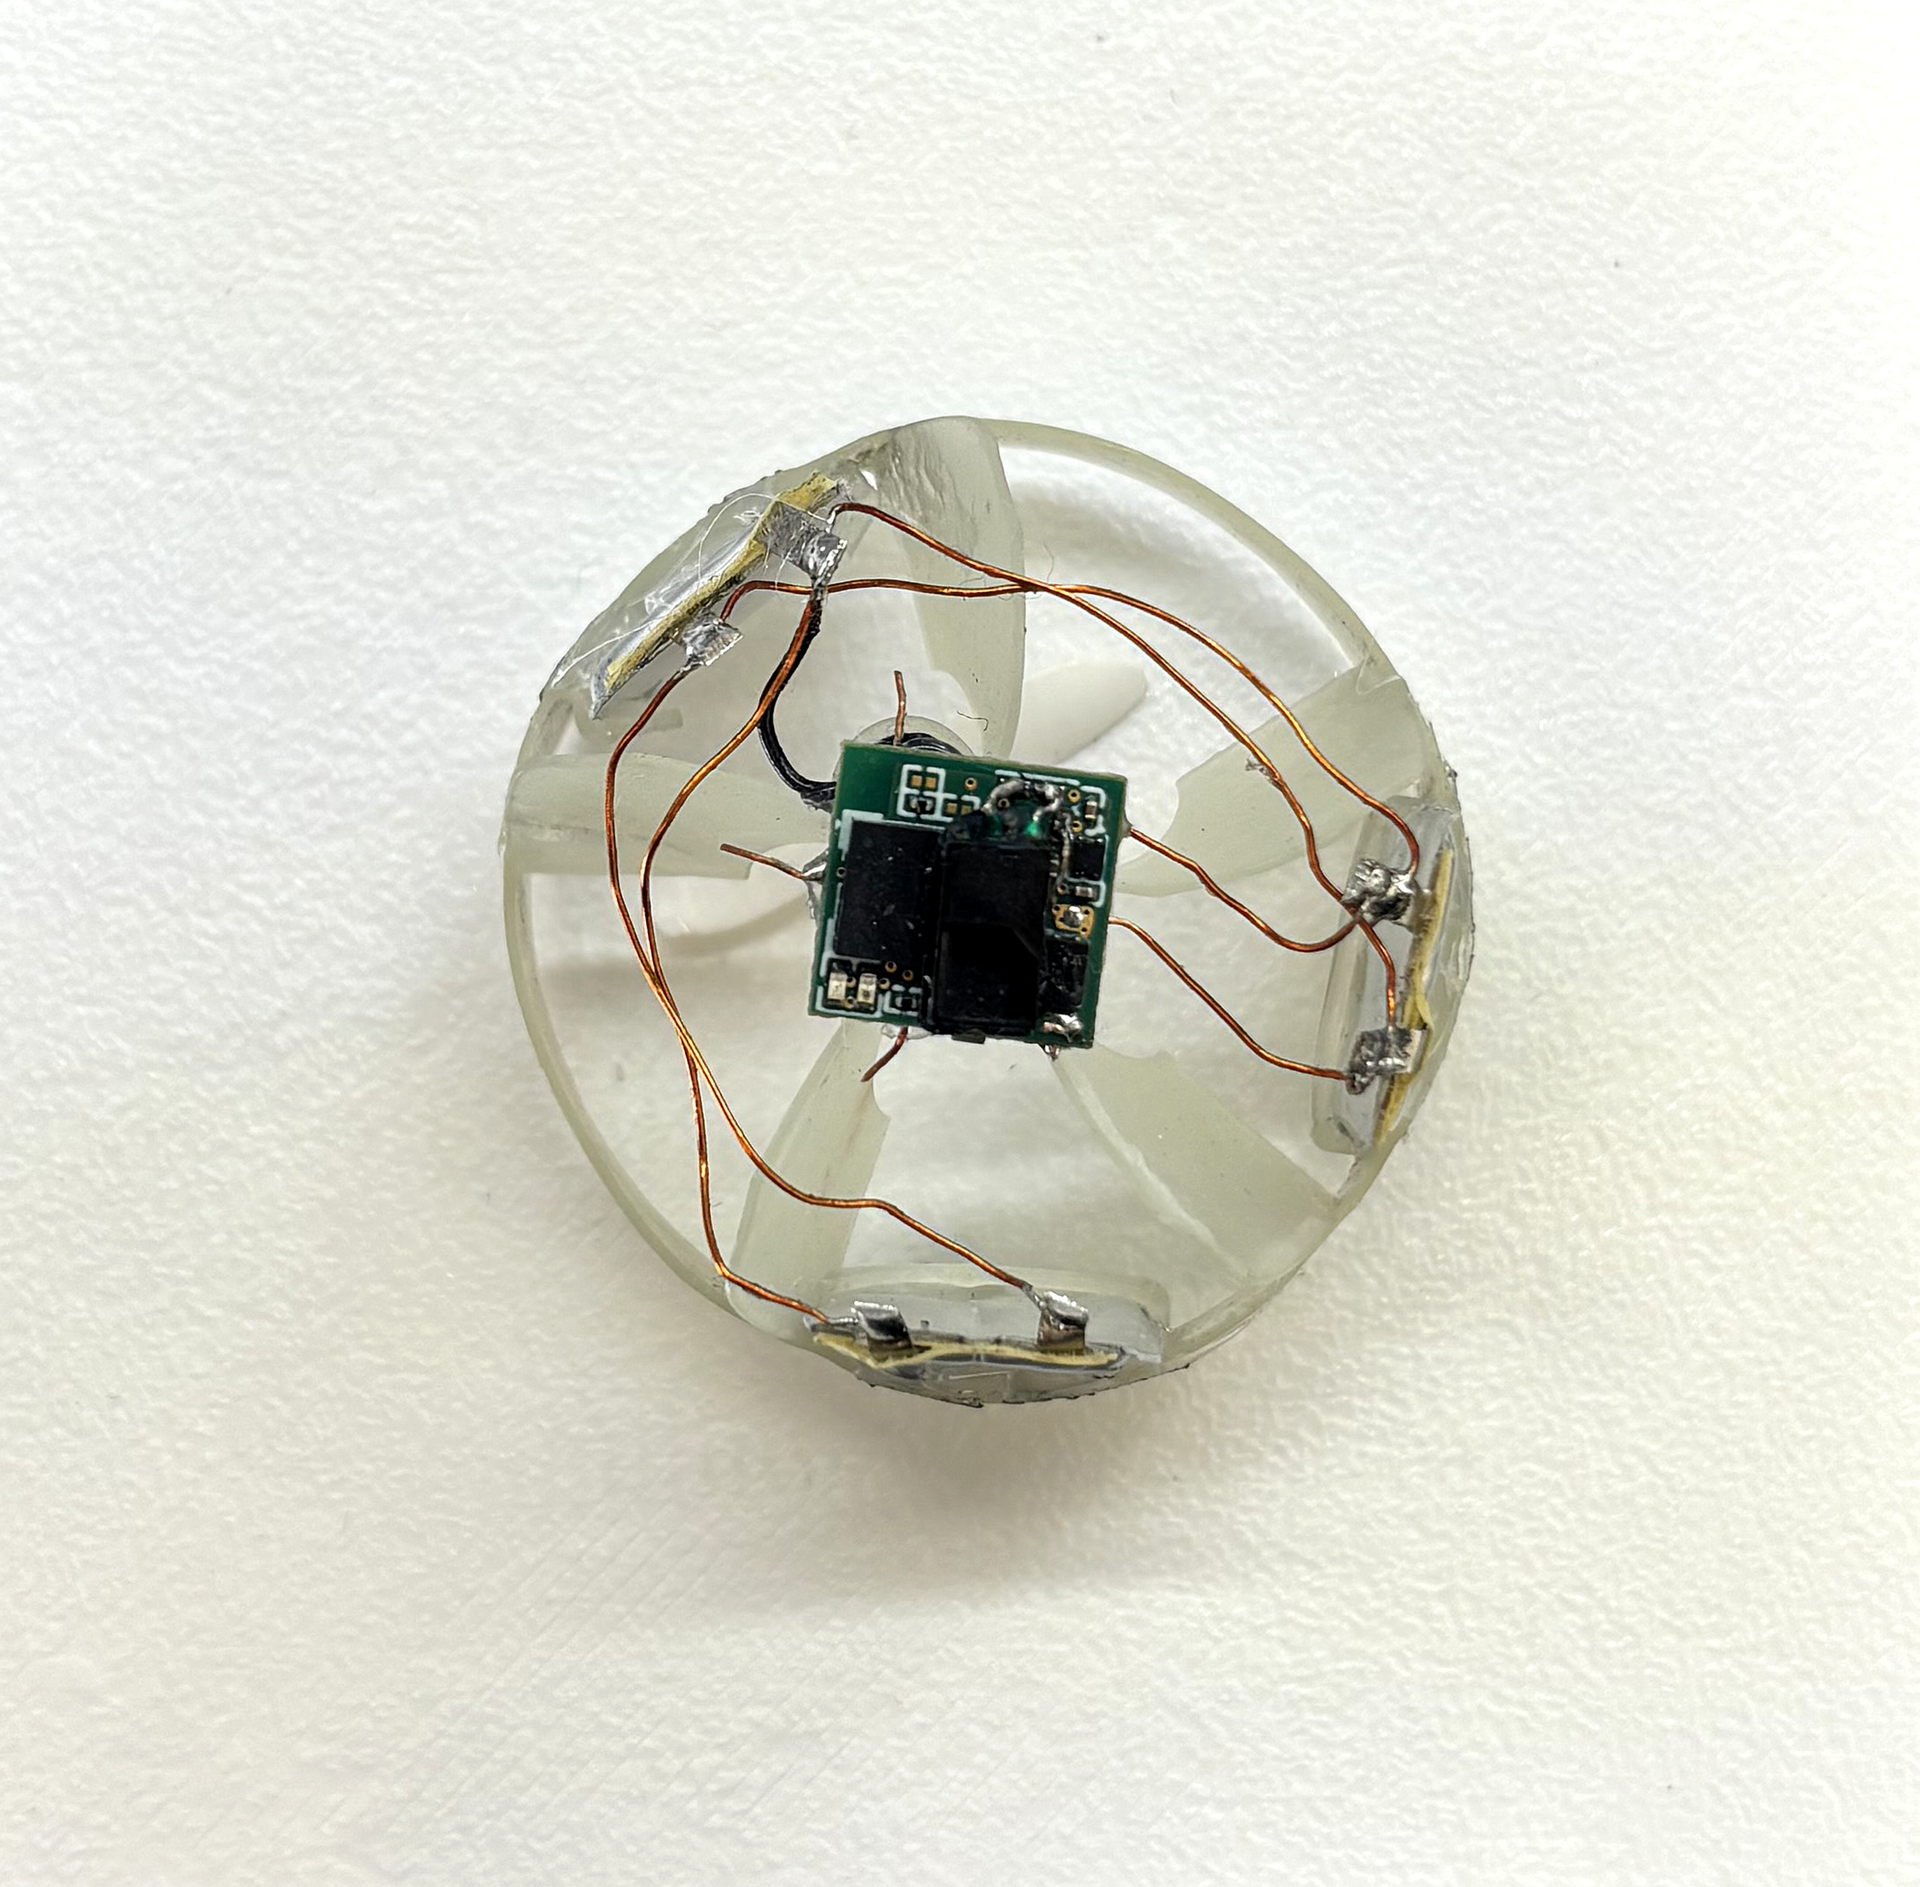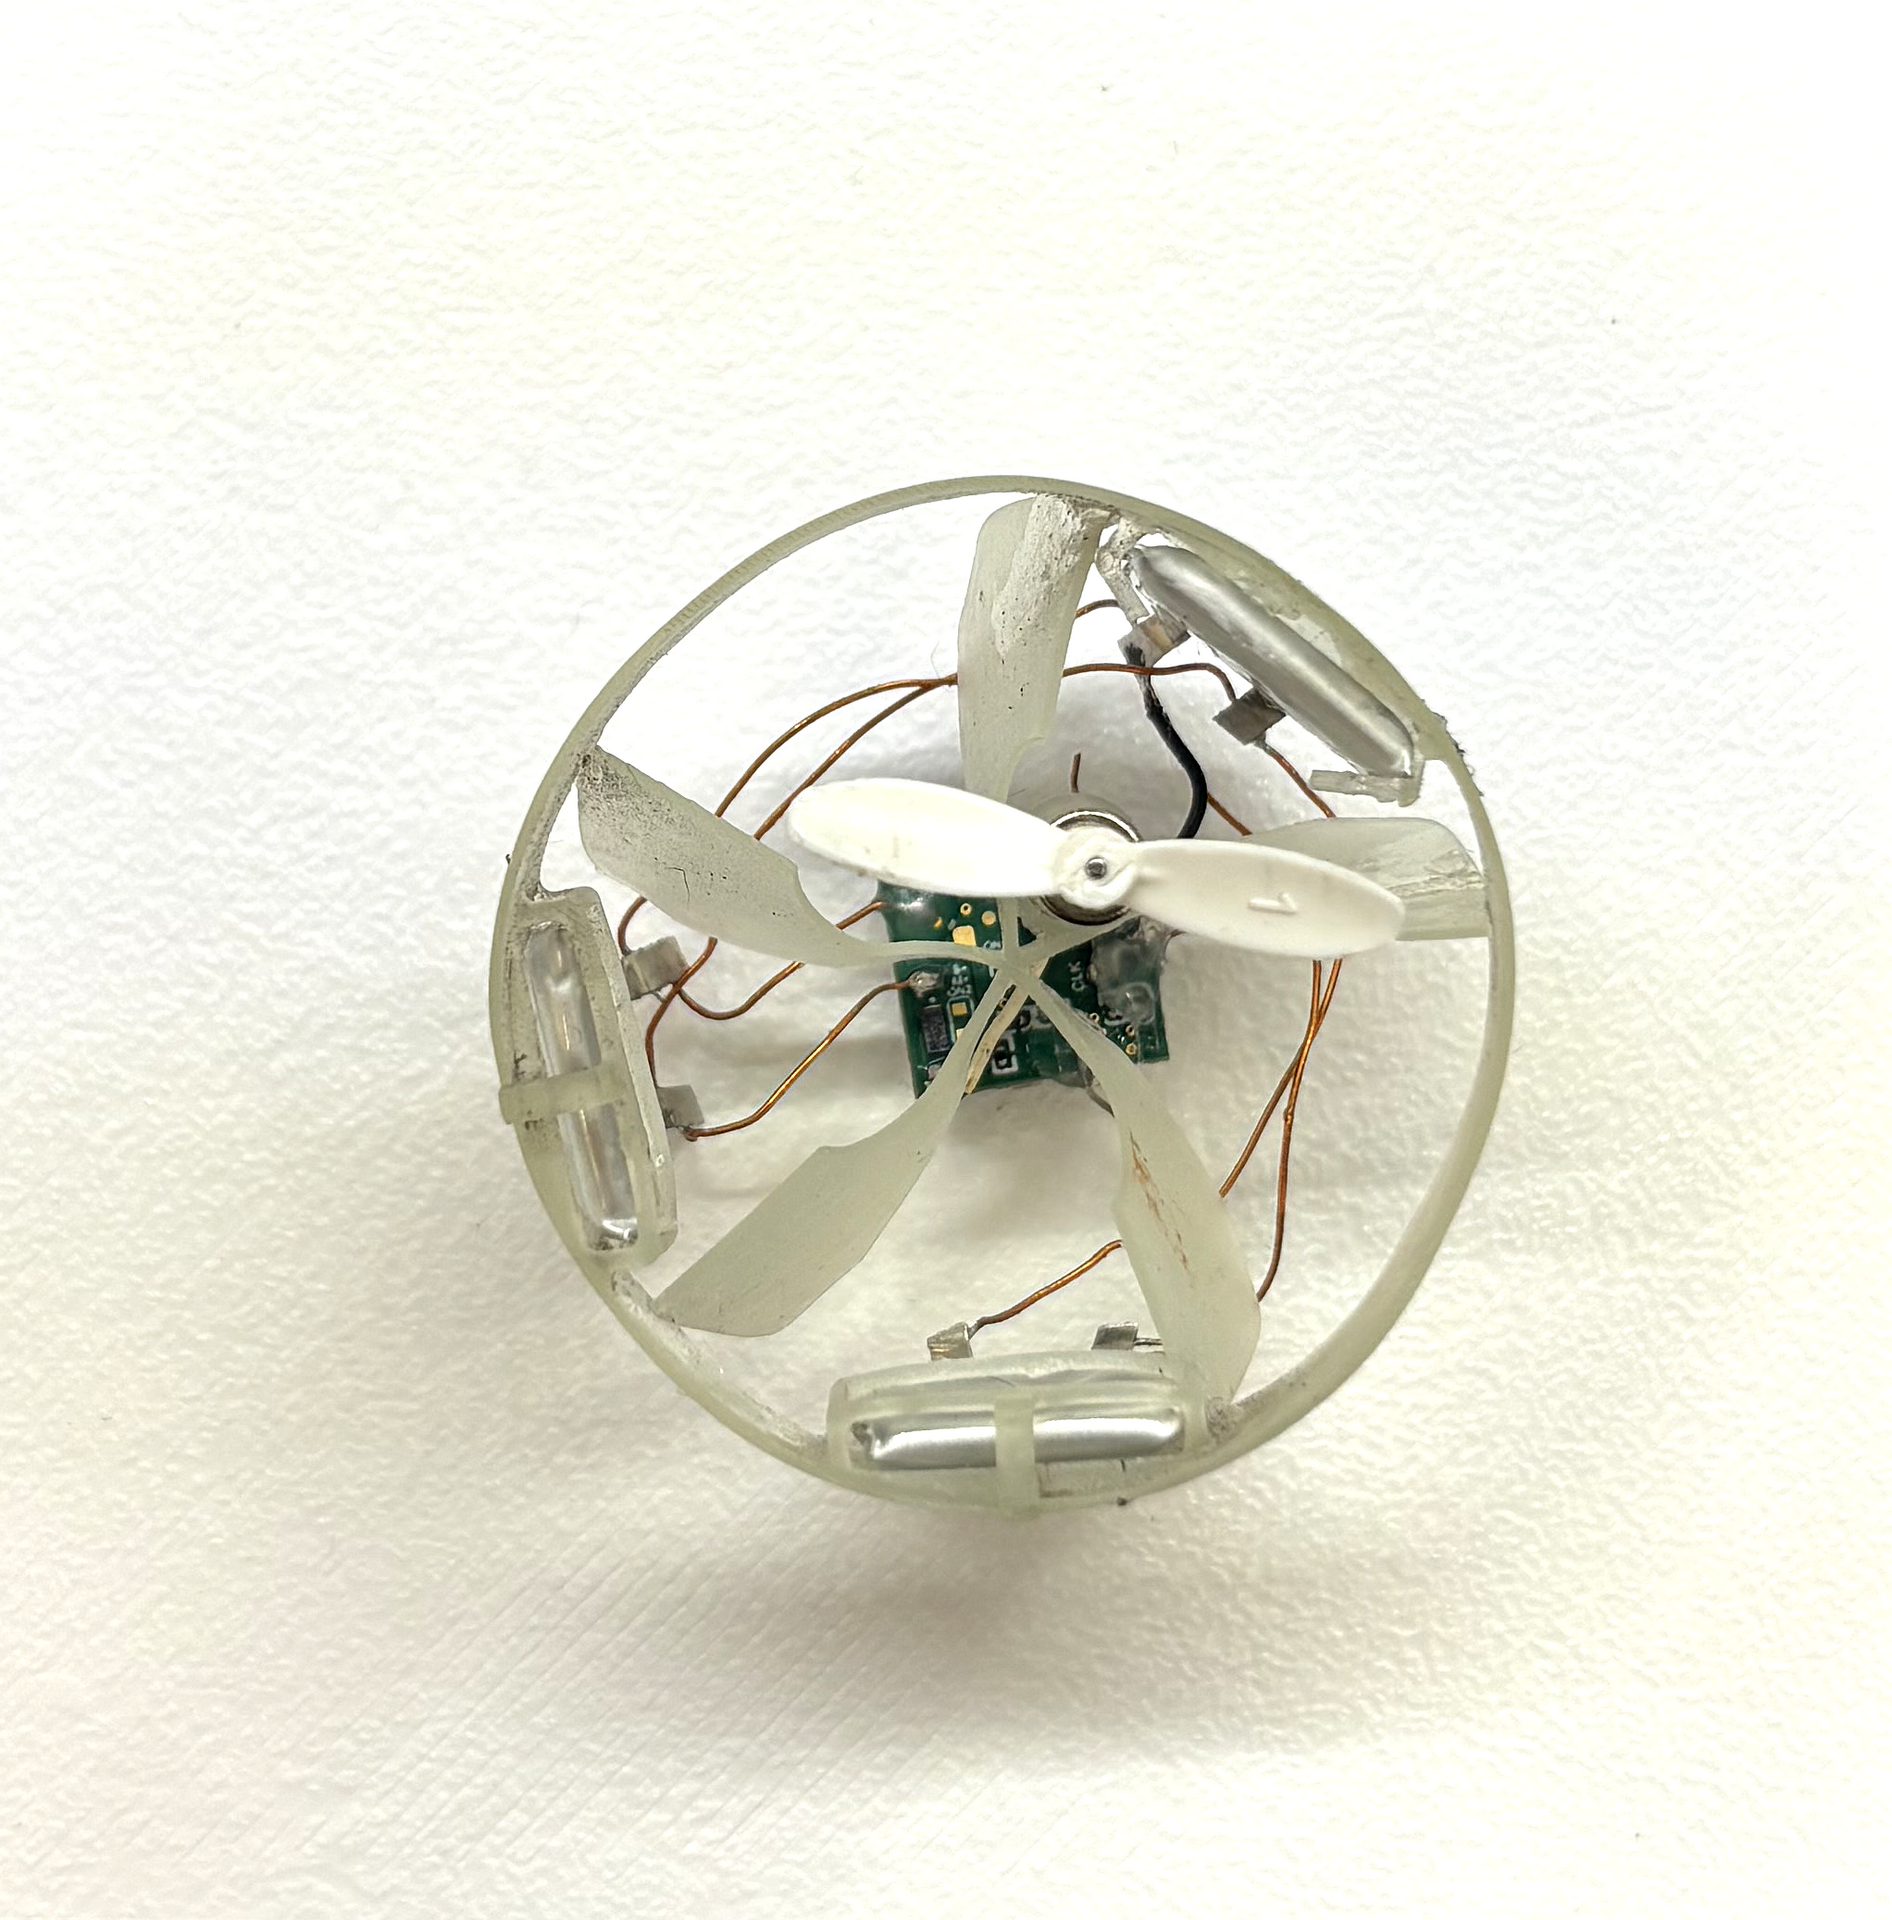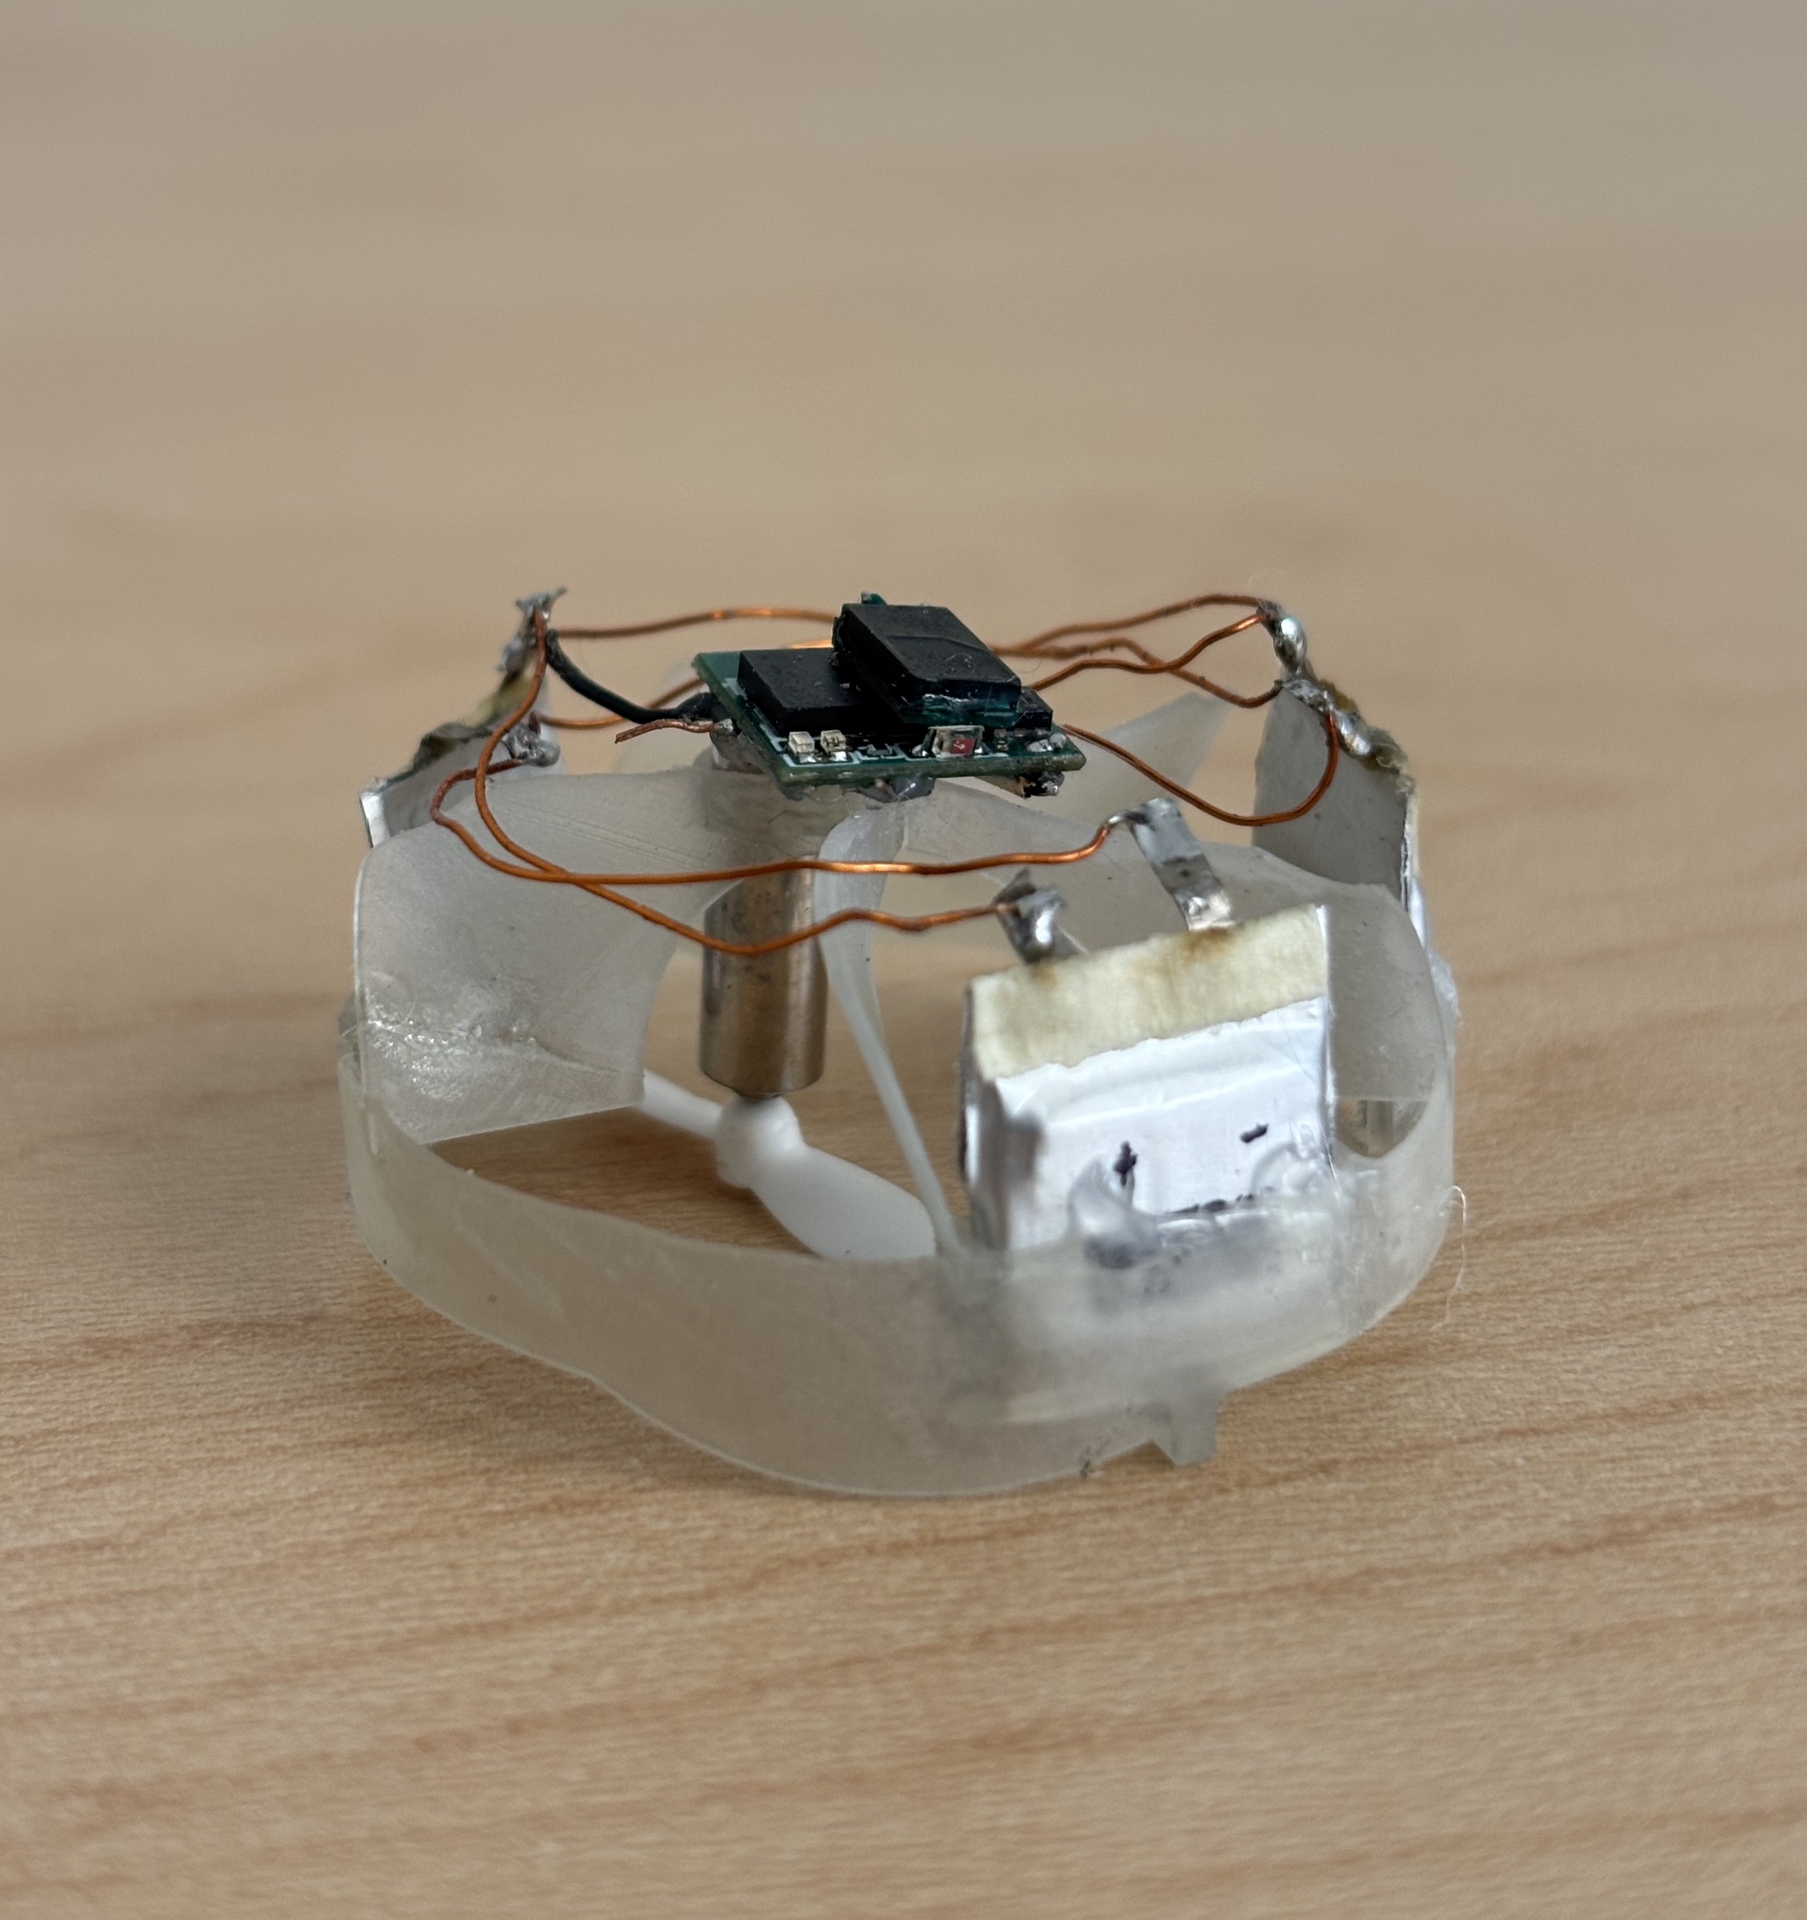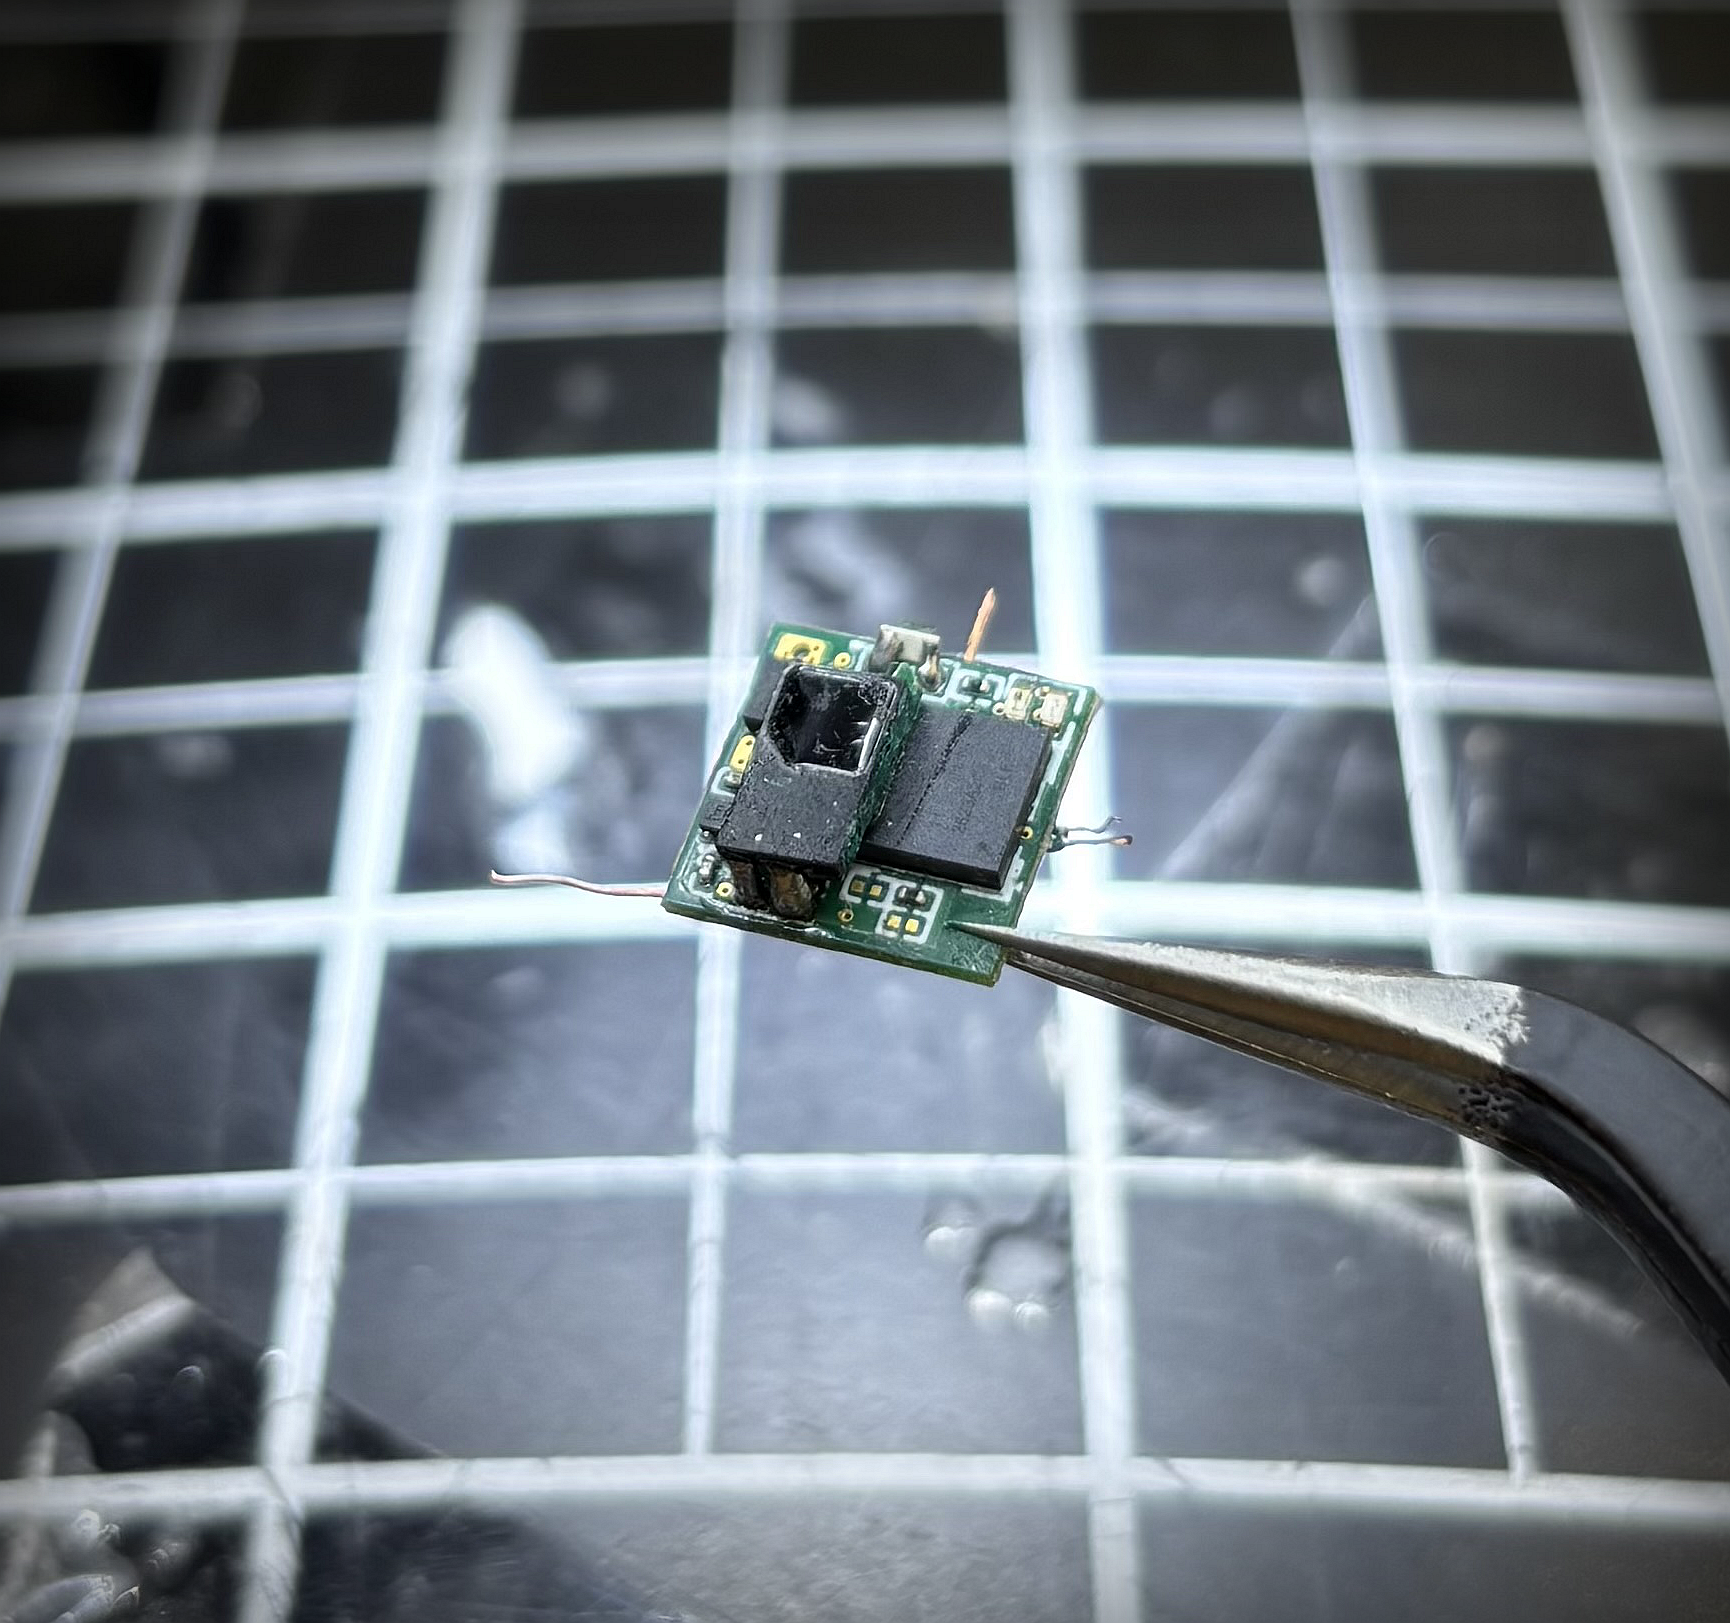
I’m Bang’an, a Master's student at the University of Pennsylvania developing gram-scale micro aerial robots, advised by Prof. Edward Steager and Prof. Mark Yim.
My research centers on MAV design and control, mechatronic system design and integration, and bio-inspired design. How can we balance power, actuation, and weight under tight design constraints? How can robots achieve versatile motion with minimal, low-cost components? Through multidisciplinary design, I aim to create systems in which mechanics, electronics, and control come together with simplicity, precision, and purpose.
For the best viewing experience, please view this site on a desktop.
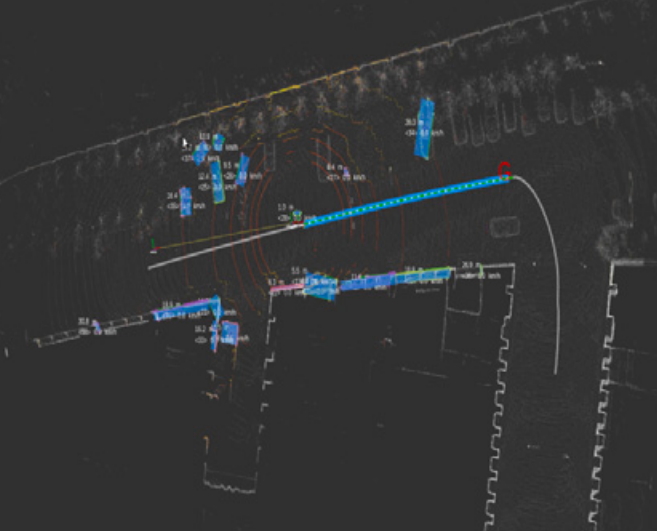
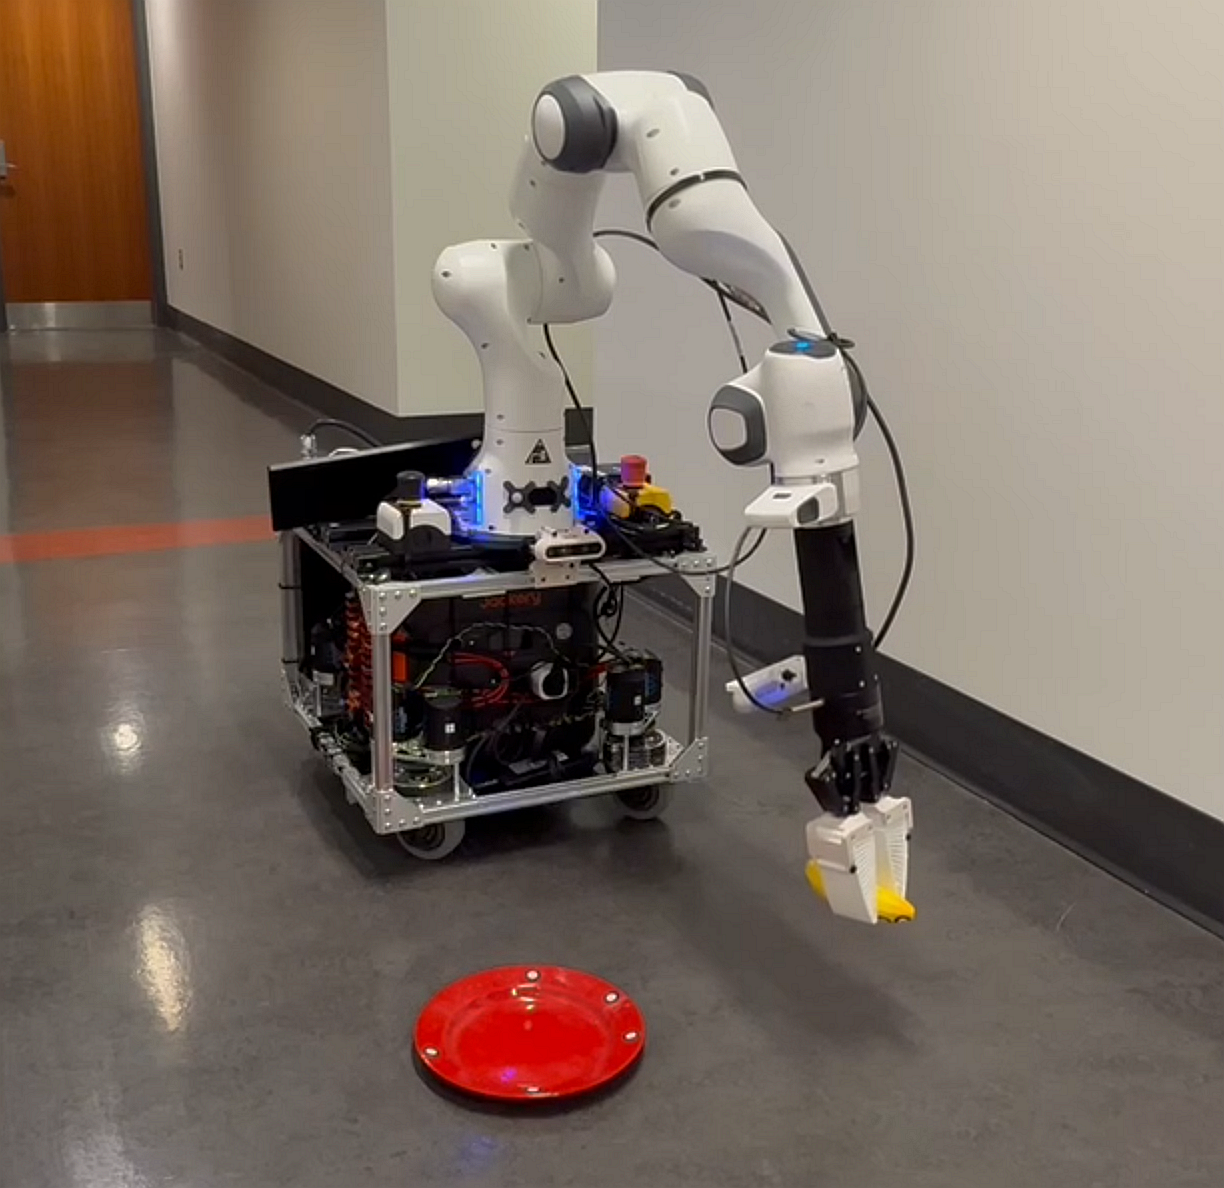
SafeDrive Dreamer is a safe reinforcement learning framework that uses a world model to roll out candidate trajectories, filter unsafe options, and select actions based on predicted reward and risk.
The policy is first trained across broad simulated scenarios, then adapted through a PAC-Bayesian safety bridge before hardware deployment. On a physical vehicle, it traveled up to 13.8% farther before requiring intervention than baselines in complex scenarios.
This research was published in Alexandria Engineering Journal.
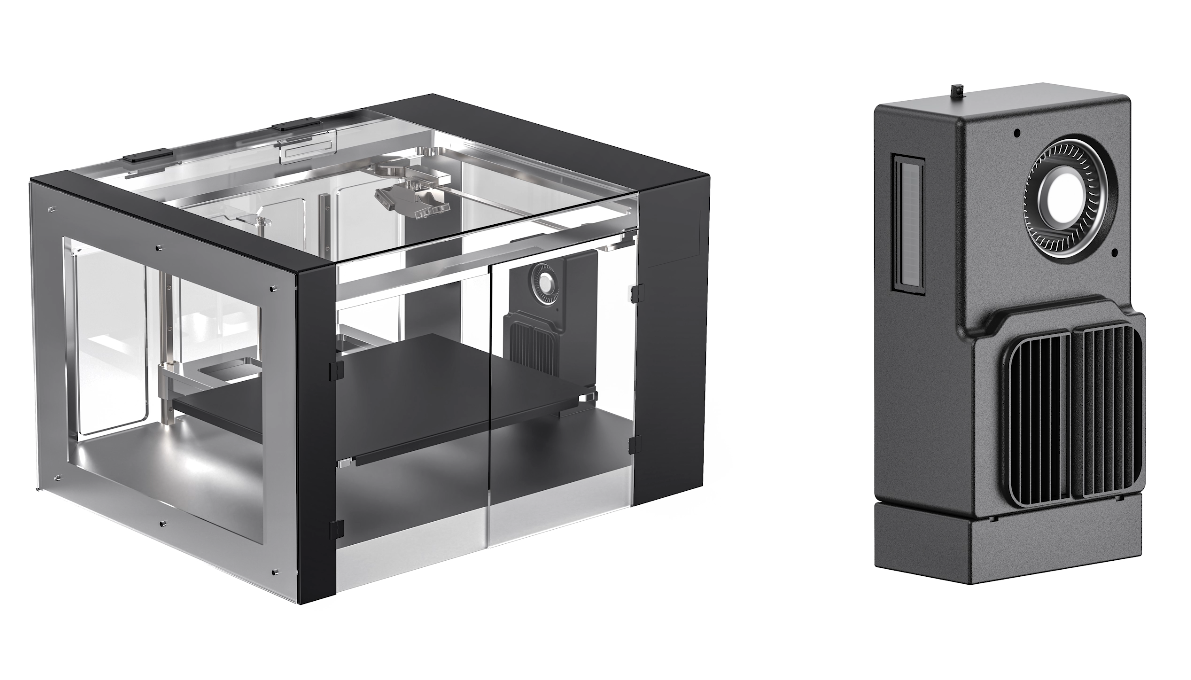
Thermal Control Unit for CFC 3D Printing
A closed-loop chamber thermal control unit for the Anisoprint A3 continuous-fiber composite 3D printer, built for ARL-MLS Lab .
It enables stable operation from 40 °C to 65 °C, maintains the setpoint within 0.5 °C with less than 0.5 °C fluctuation, and achieves ±2 °C temperature uniformity throughout the 793 × 640 × 420 mm chamber.
🥇 1st Place · 2024–2025 MIE Senior Design Competition
Department of Mechanical & Industrial Engineering, University of Toronto